About the lab
Robots that move, sense and adapt
The Robotics Locomotion and Control (RLC) Laboratory is part of the METU Center for Robotics and Artificial Intelligence (ROMER) and the Department of Electrical and Electronics Engineering.
We combine control theory, system identification and experiments on real robots — from legged machines and marine vehicles to lunar rovers.
The lab at a glance
7
Ph.D. students
4
M.Sc. students
25+
Graduated theses
8
Ongoing funded projects

Featured project
CHERI: Twin Rovers for the Lunar South Pole
Two shoebox-sized autonomous rovers developed at ROMER will explore the Moon’s South Pole on China’s Chang’e-8 mission. RLC works on their locomotion, gait control and simulation.
Research
What we work on
Feedback Motion Planning
Sparse, trajectory-free planning for surface, underwater and ground vehicles.
System Identification
Time-periodic, hybrid and Koopman-based models of rhythmic systems.
Facilities
Where we test
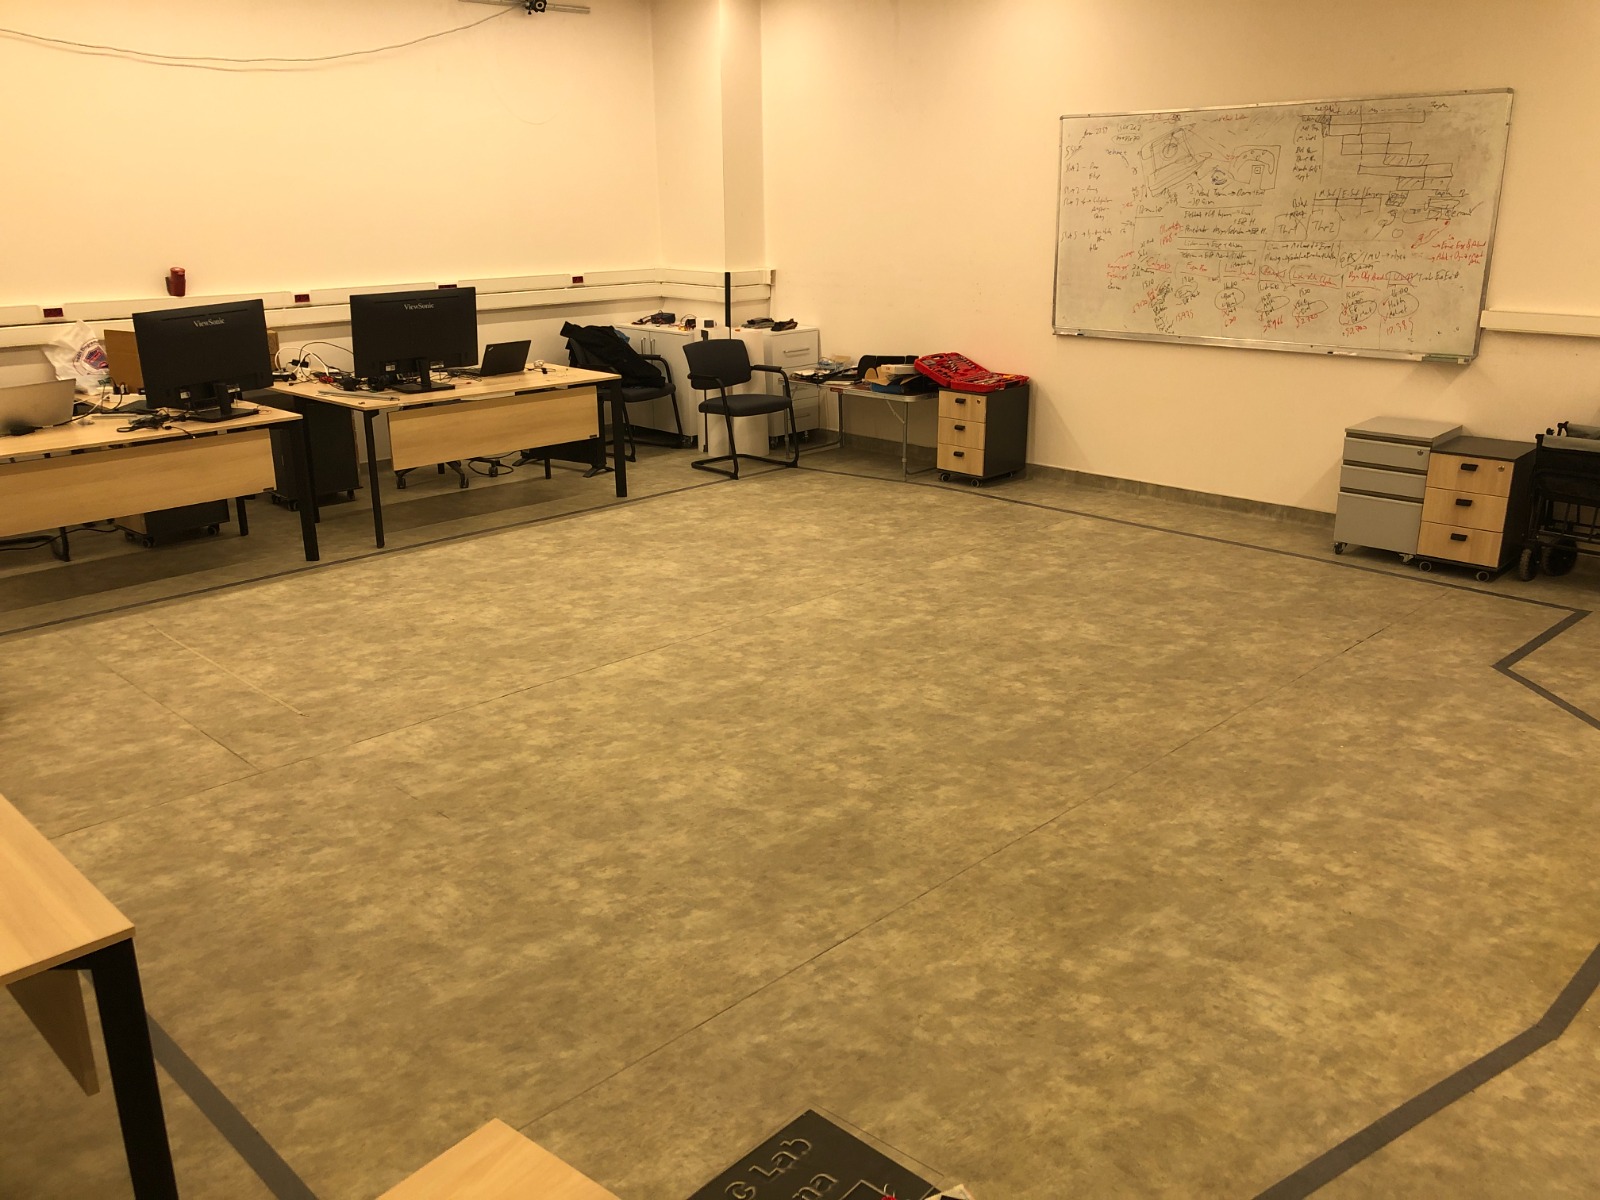
Motion Capture Laboratory
Precise tracking of robot motion for studying locomotion dynamics and validating controllers.
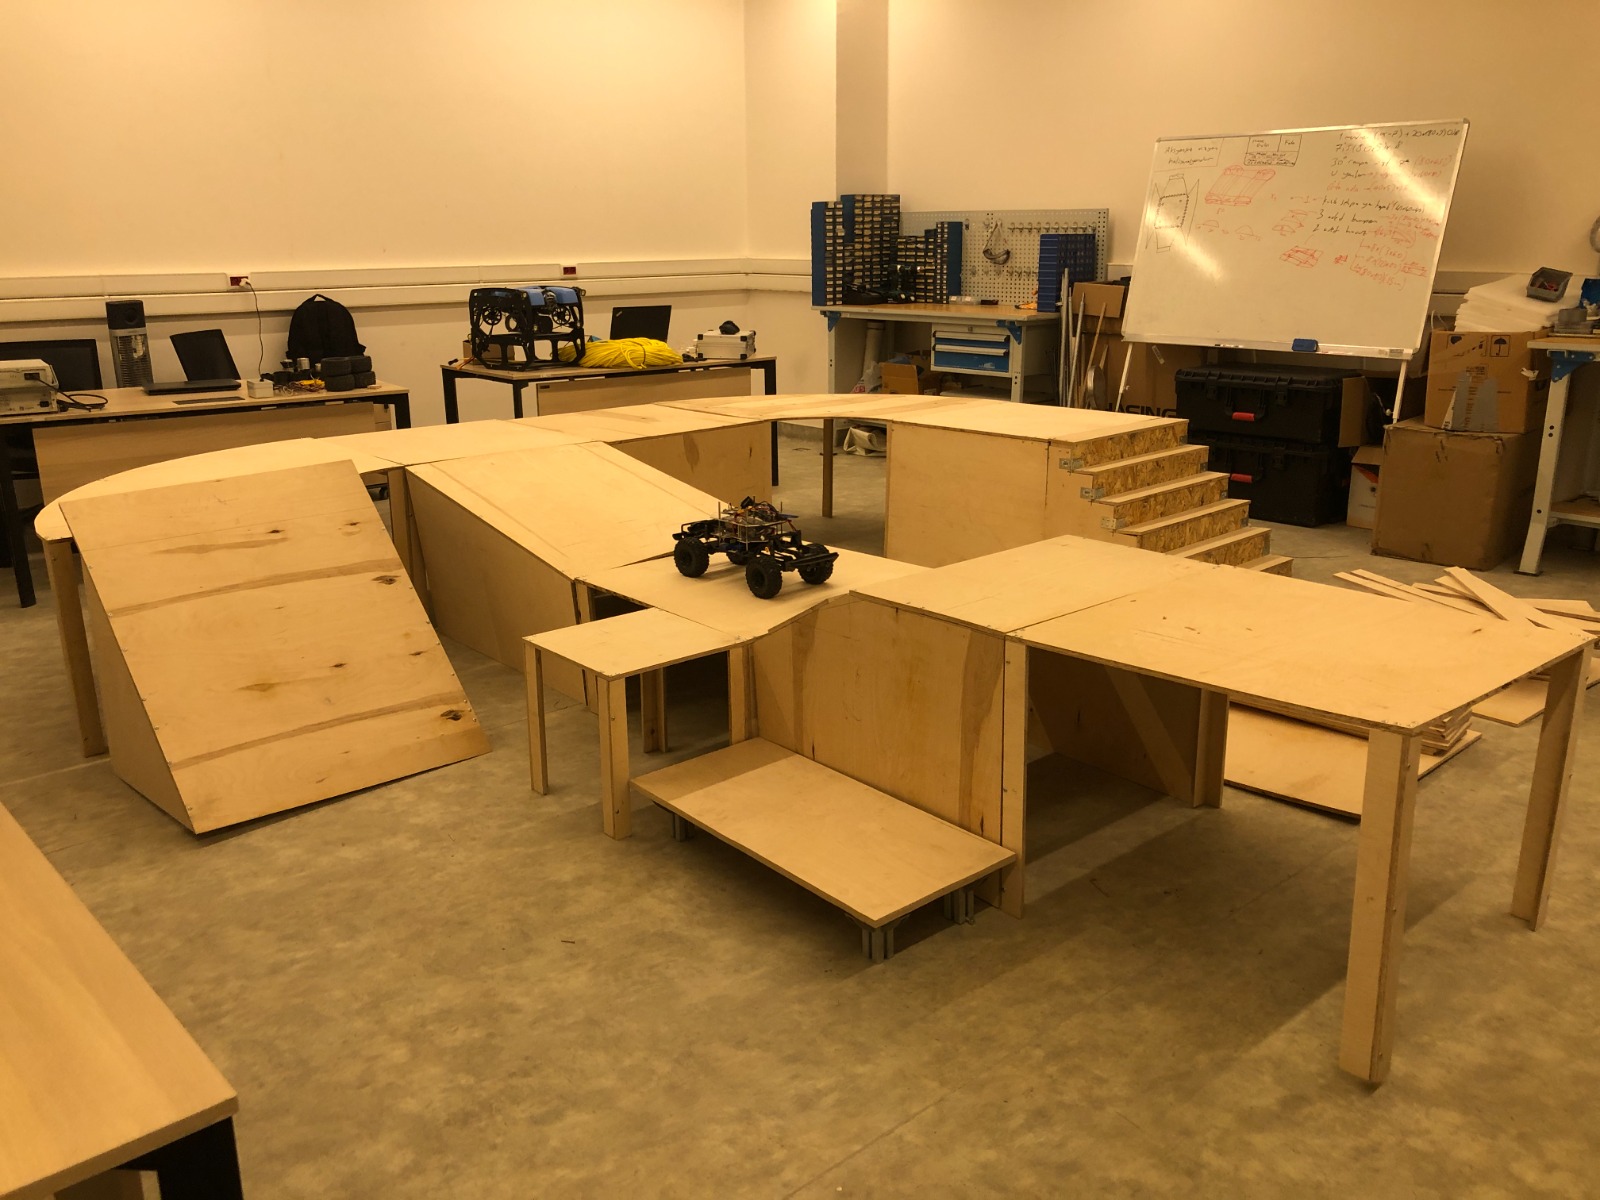
Robotic Mobility Arena
Off-road arena with bridges, tunnels and uneven terrain, paired with an indoor 3D localization system.
Terrain Simulator
Sand landscapes that mimic deserts, lunar and Martian surfaces for testing rovers in realistic conditions.
Latest news
Recent highlights
2026
METU’s two CHERI micro rovers will be deployed to the lunar South Pole on China’s Chang’e-8 mission.
2026
TÜBİTAK 1005 project E-VIN on event-camera-aided inertial odometry started.
2026
Papers at ECC, BioRob, AIM, ICIP and SIU 2026.
2025
YÖK Superior Achievement Award for the ASELSAN–ROMER legged robotics collaboration.
2025
Journal papers in J. Bionic Engineering and Bioinspiration & Biomimetics.
Join us
Interested in working with us?
We look for motivated M.Sc. and Ph.D. students who enjoy building and testing real robots.